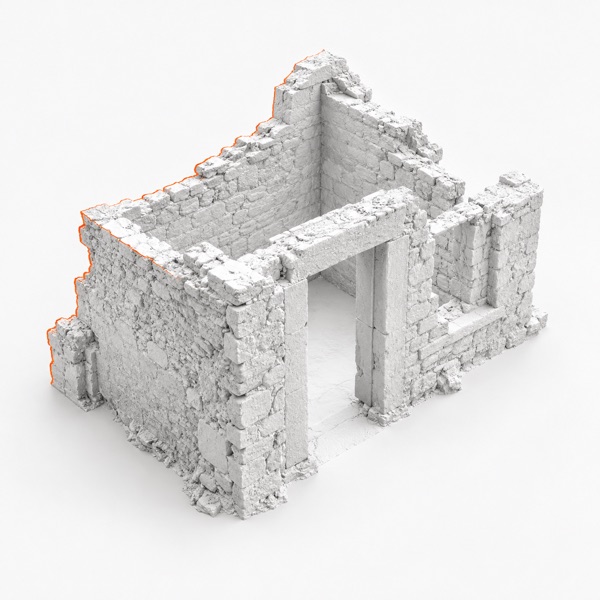
Rebuilding the scene
Walls, doors, stairs
0 objects
found so farUpload footage or LiDAR. Force agents rebuild the space in 3D, add real physics and turn it into robot training data.
Footage, Labels, 3D Simulations, physics, and training all in a few clicks. Force runs them as agents you can watch, check and stop.
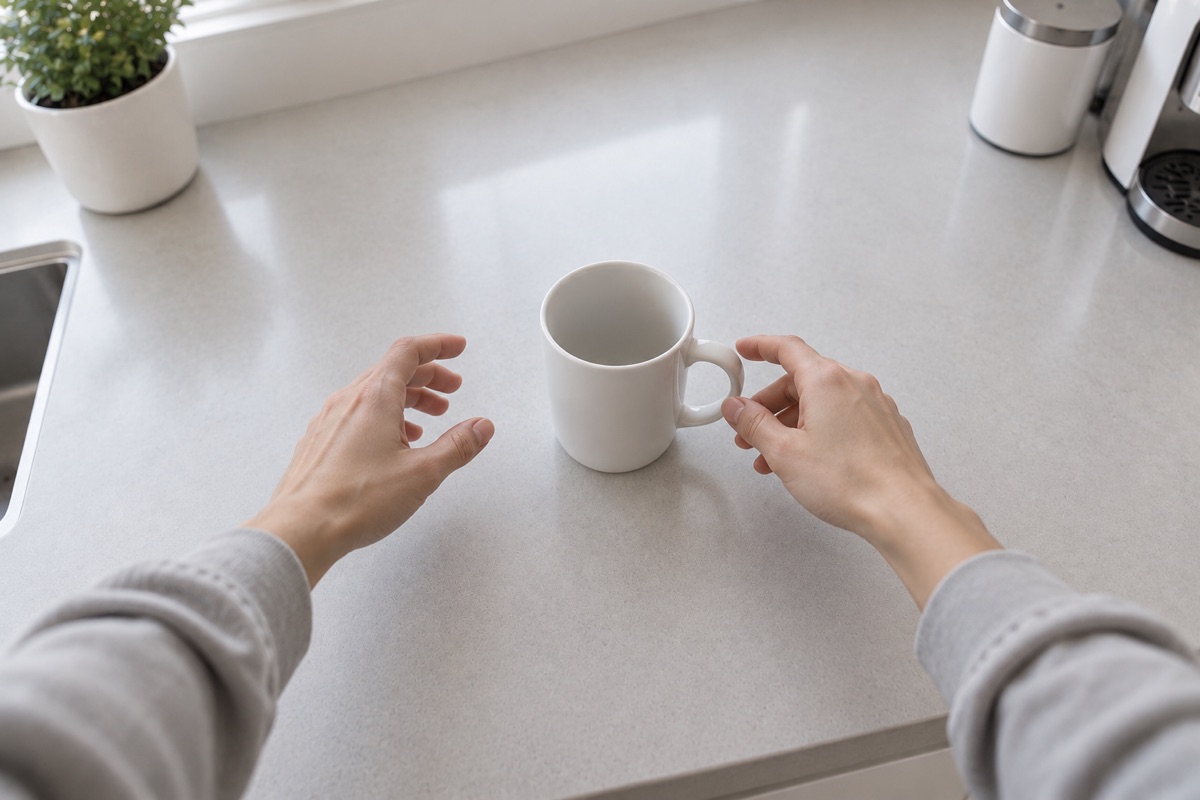 REC 00:12:31CAM 3, Helmet, 1080p
Review footage
Downloading, clip 1 of 31
Label hand actions
Starts after step 1
Rebuild the scene
Waits for your yes
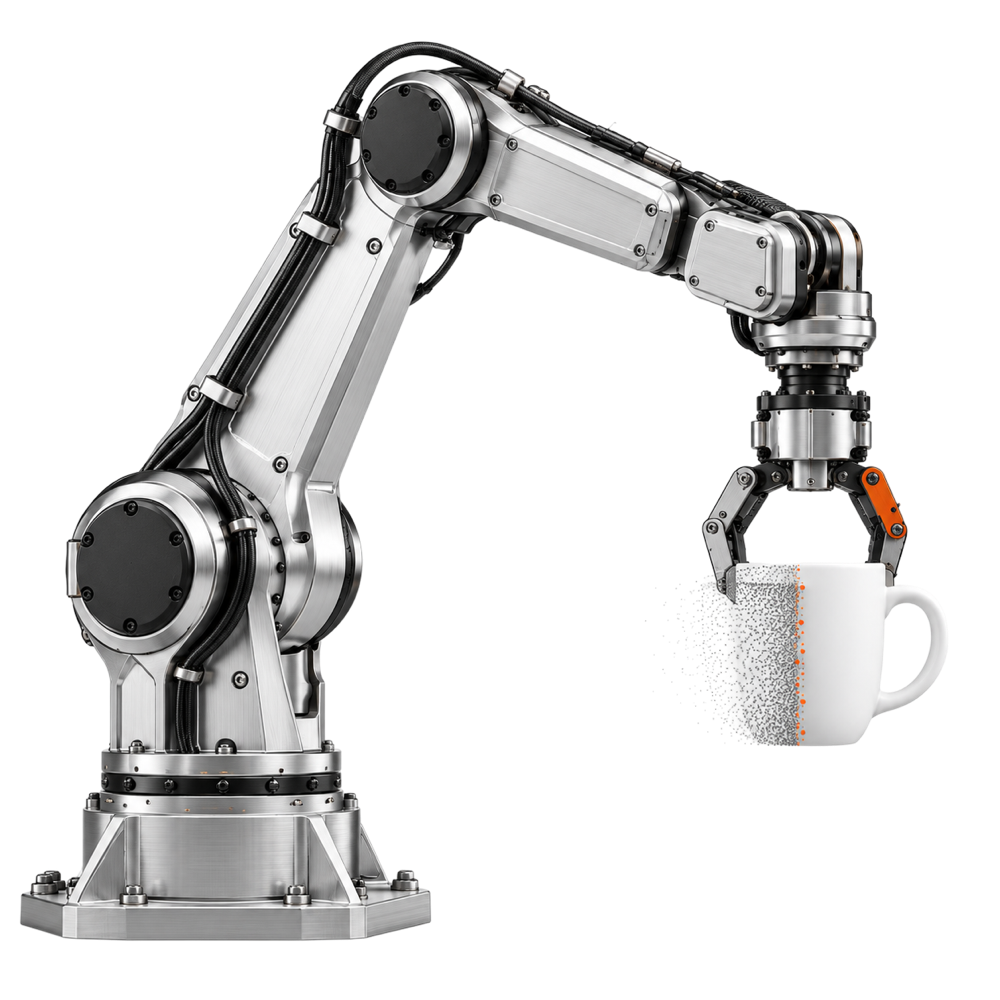
Train the robot
Starts after step 3
3 steps: You answer a few questions in the chat and approve or reject anything that changes and let the Force agents do the rest.
Upload footage or LiDAR
Drop clips in, or point Force at S3, Google Cloud or your own server. Helmet cams, phones and LiDAR scans all work.
Agents label, rebuild and add physics
Every hand action is labelled with a timestamp. The space is rebuilt in 3D at real scale, with mass, friction and joints.
Train and test the robot in sim
Describe the task in one sentence. Watch the robot try it next to the person who did it, then export to your simulator.
Every action gets a color, a timestamp and a confidence score. The space behind it becomes a measured model a simulator can use.
left handright handMug, 0.32 kgCAM 3, Helmet, 0:00.0both, Hands at rest98%Door 1, 2.1 × 0.9 mBefore LiDAR, 7.85M pointsAfter Reconstructed meshIf a person can do it on camera, Force can turn it into data a robot learns from.
Scene 1, KitchenHelmet-cam footage of people cooking and cleaning becomes pick, place and pour demos.
- actions labelled
- 51
- objects
- 20
- pick success
- 97.8%
Type the task. Force finds the moment in your footage, gives every object real physics and shows the robot doing it next to the person who did.
- Found the grasp in clip 1 at 0:04Action labeller
- Matched the mug, 0.32 kg, friction 0.6Physics estimator
- Replayed the human demo in the kitchen sceneRobot gym
- Trained across 500 variationsRobot gym
Ready to export, USD, MJCF
- Grip force
- not yet
- Lift
- not yet
- Slip
- not yet
- Match to human
- not yet
Works with
- Amazon S3Footage
- Google CloudFootage
- Isaac SimSimulation
- MuJoCoSimulation
- ROS 2Robots
- OpenUSDScenes
Bring your own footage or try the sample kitchen pack. Your first run is on us.